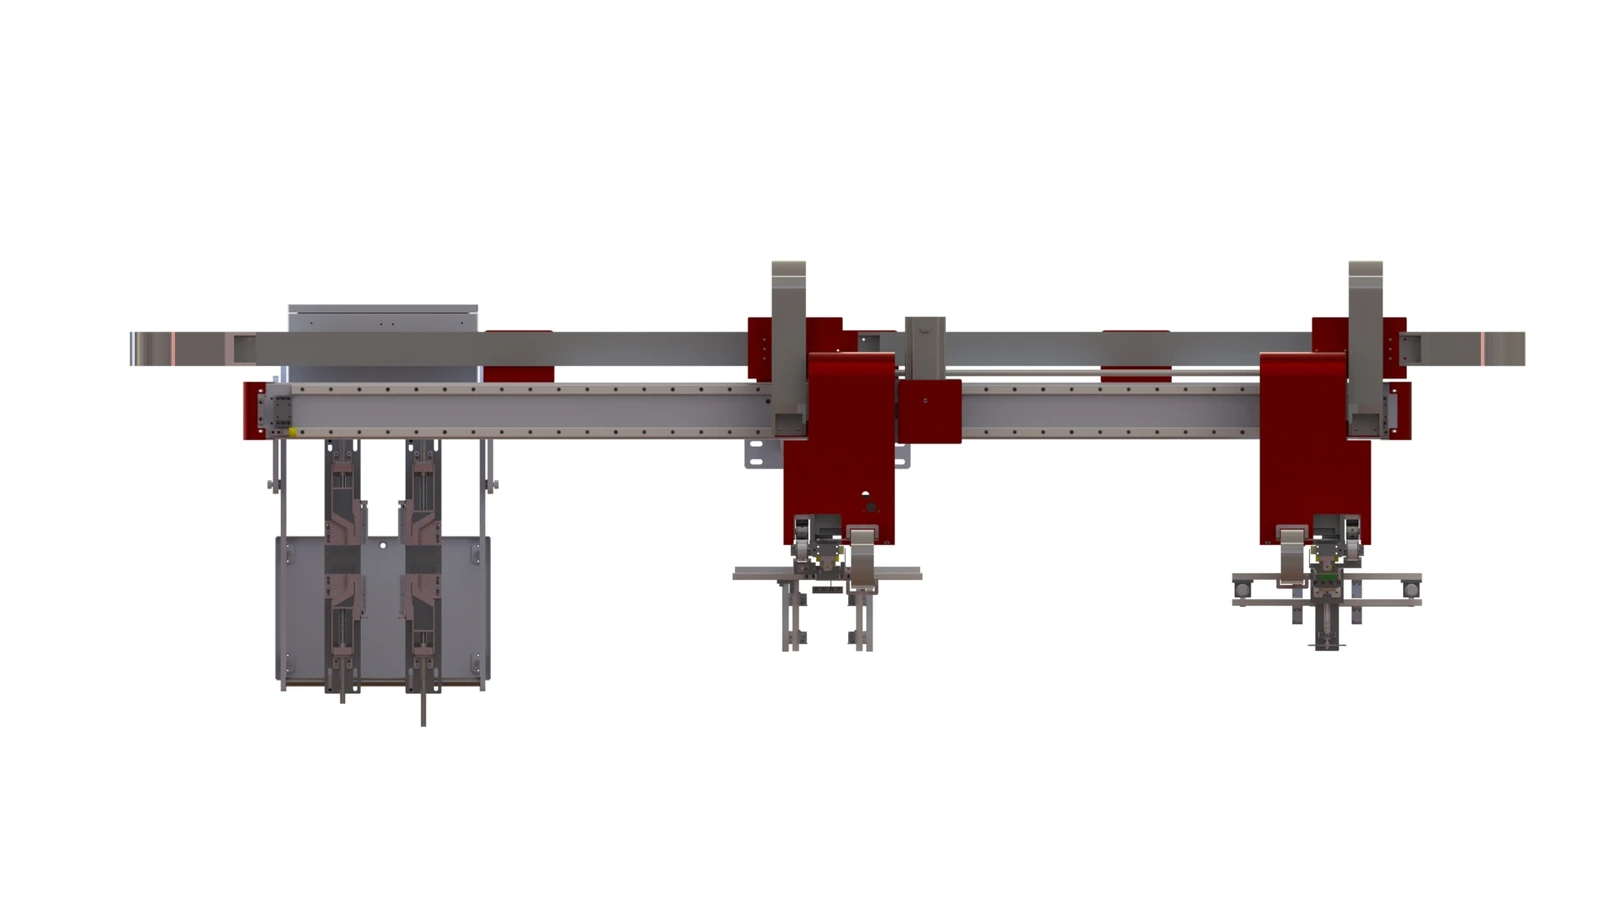
PE Christmas Tree Injection Molding Robot
Dual Level 4 Output
Dual-level wire insertion and take-out for PE branches.
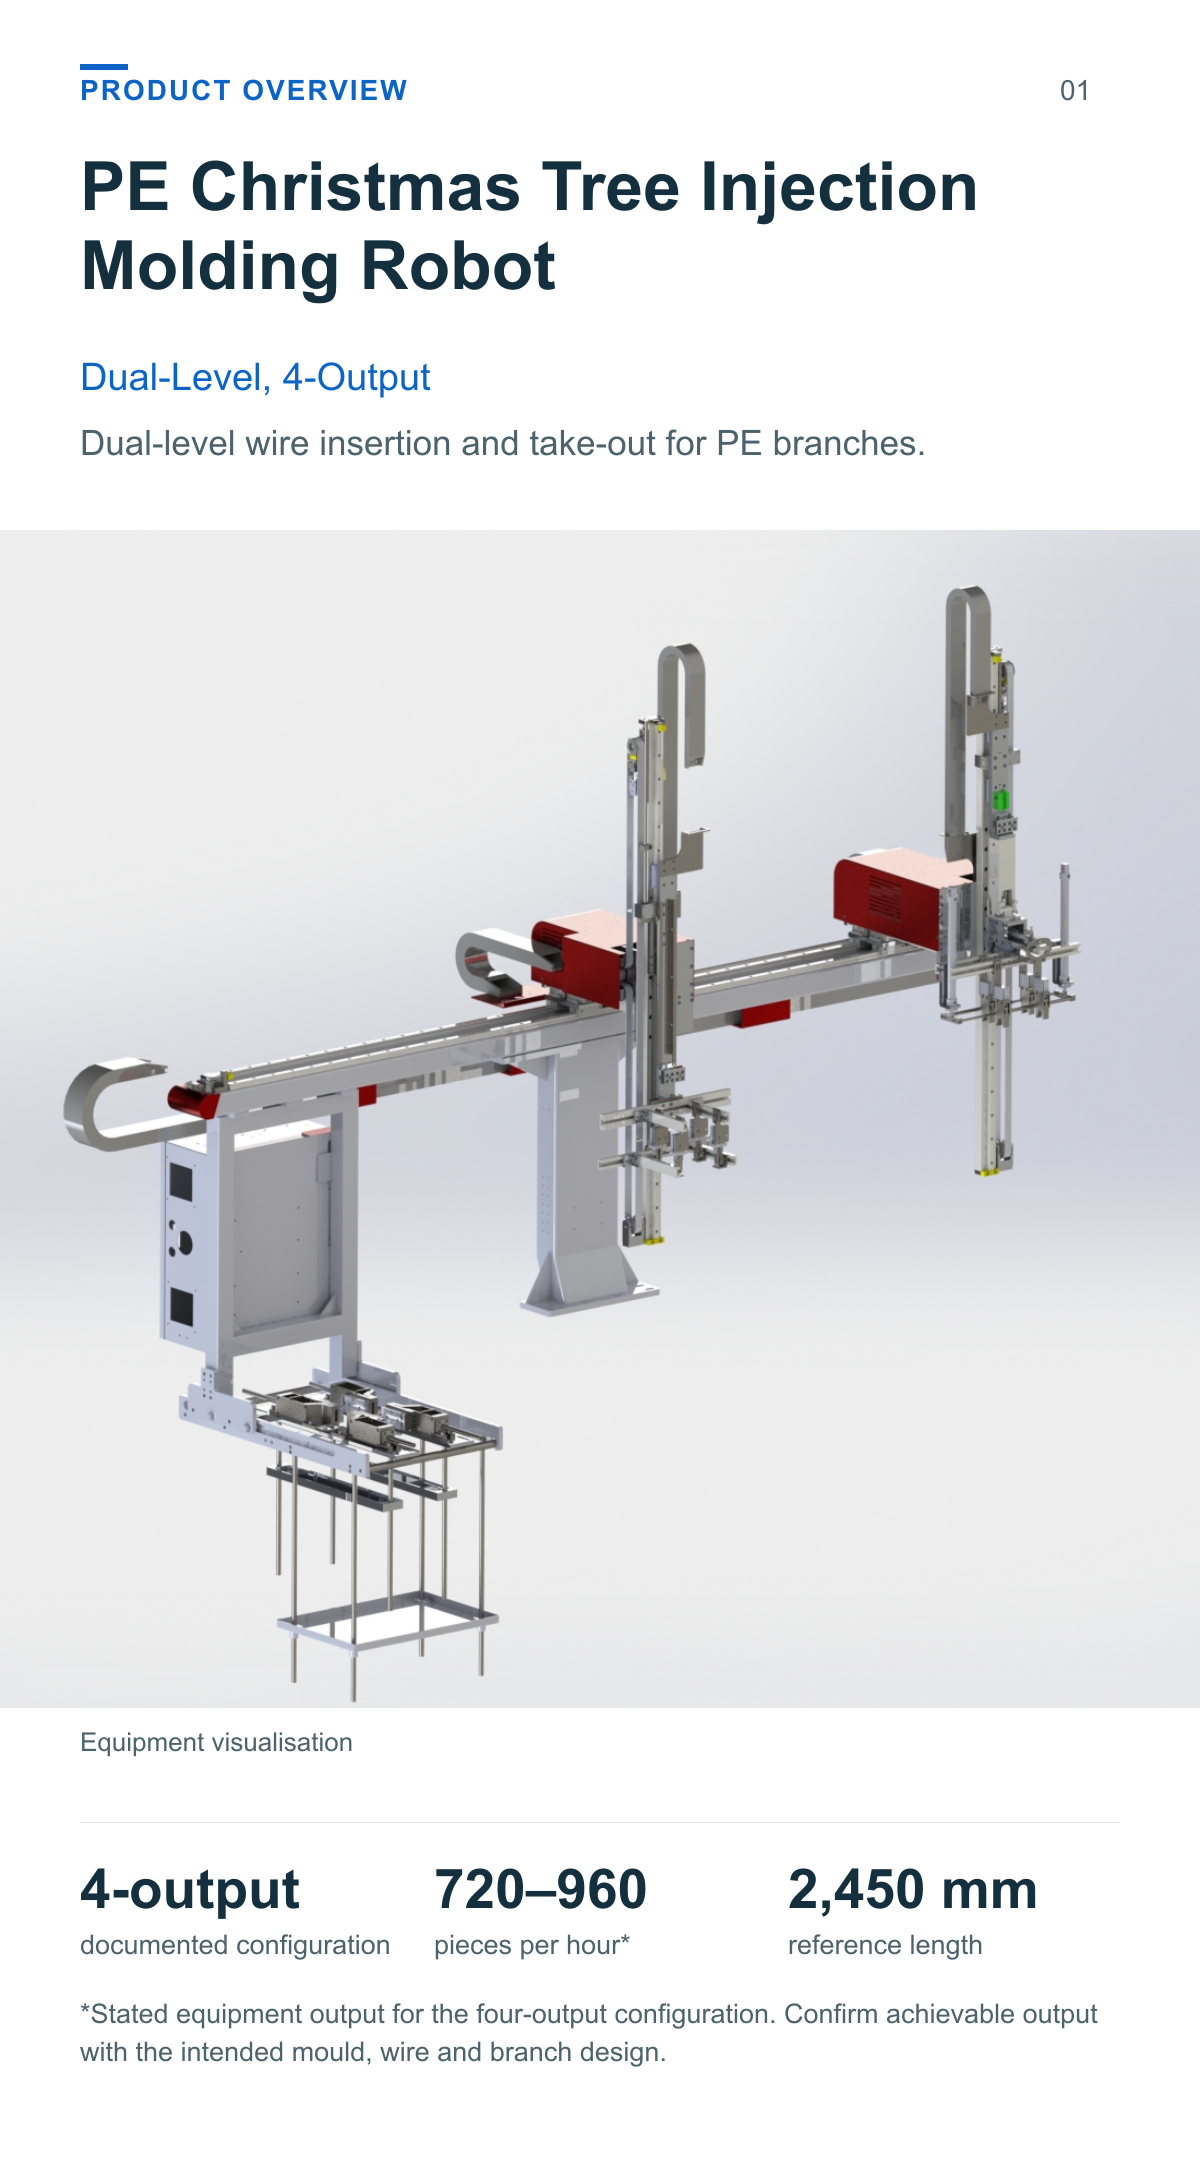
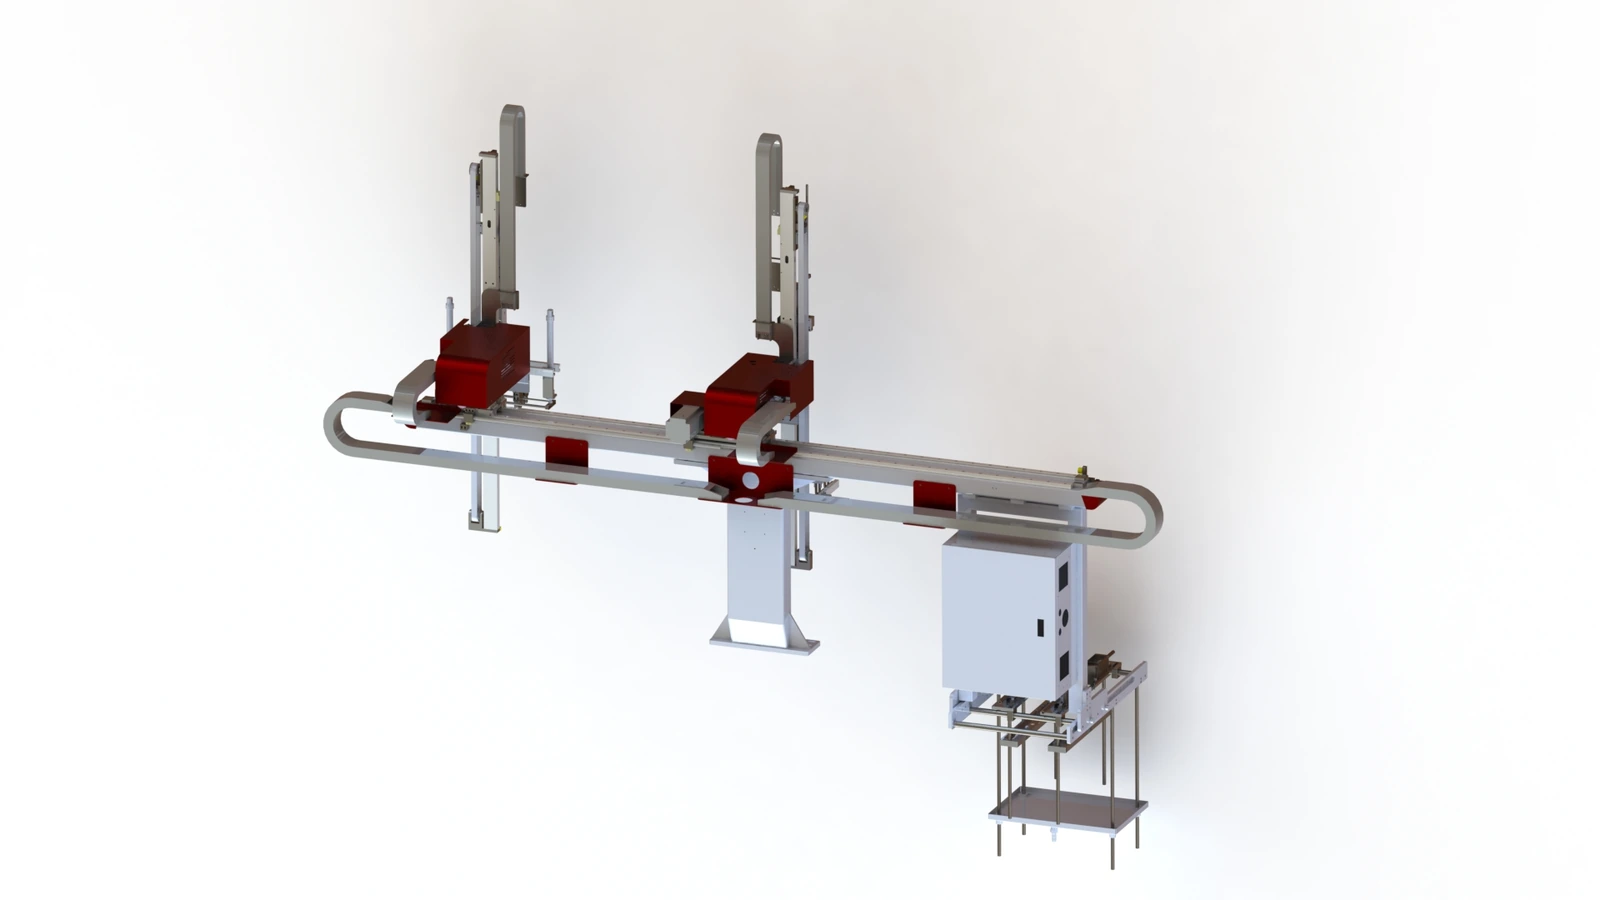
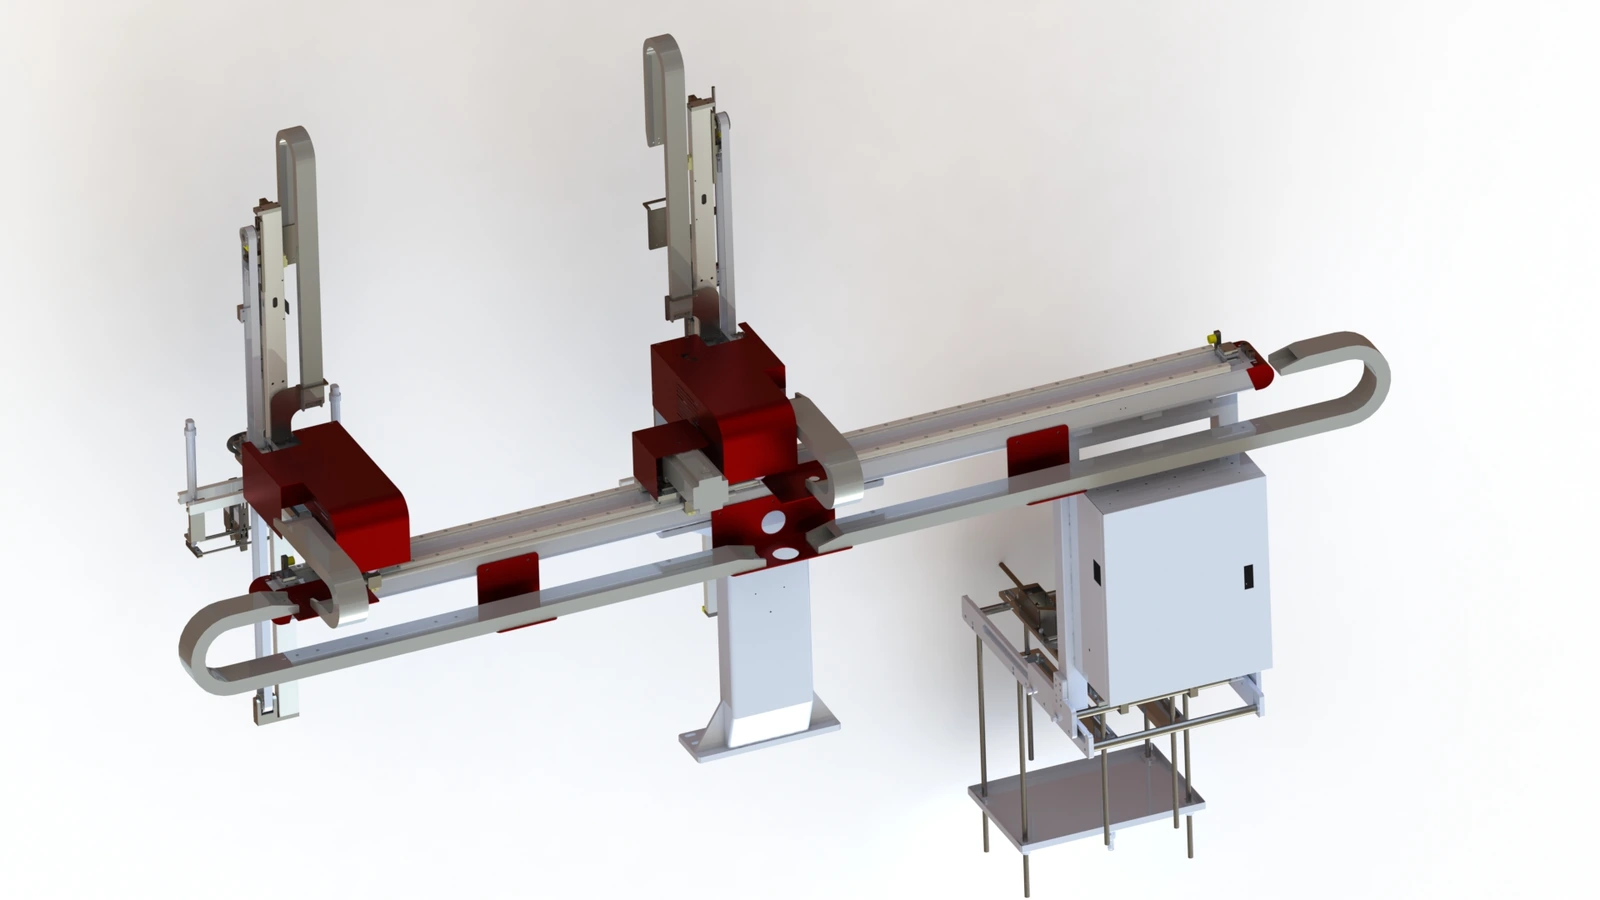
A dual-level, 4-output Christmas tree injection molding robot for PE branch production. The robot grips wires for insertion into the mould holes, takes out the moulded branches and places the products after moulding.
4-output documented configuration
720–960 pieces per hour*
2,450 mm reference length
*Stated equipment output for the four-output configuration. Confirm achievable output with the intended mould, wire and branch design.
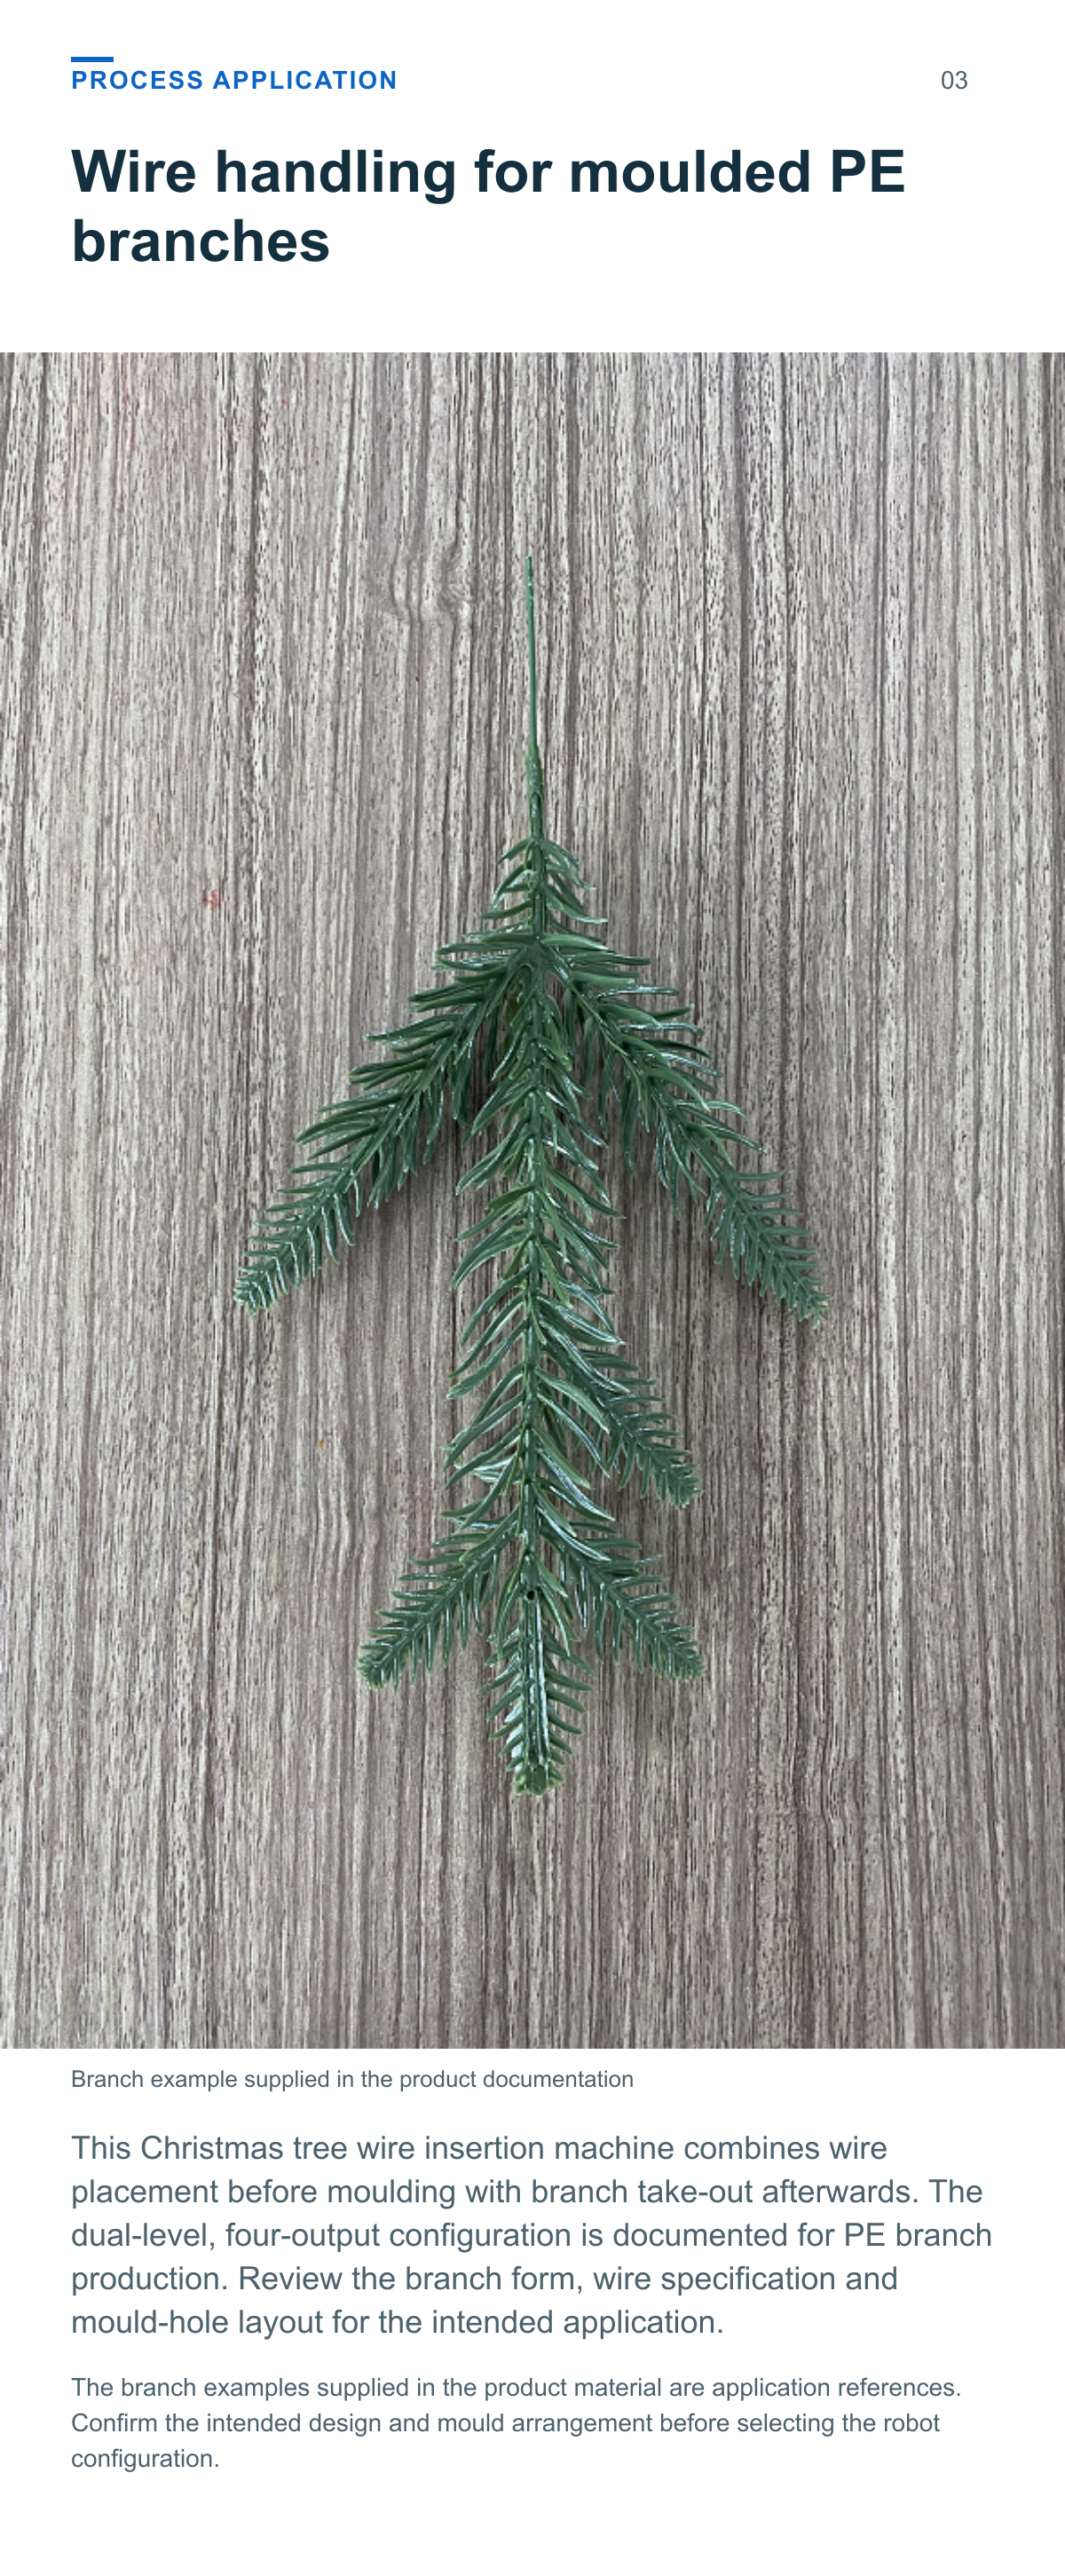
Wire handling for moulded PE branches
This Christmas tree wire insertion machine combines wire placement before moulding with branch take-out afterwards. The dual-level, four-output configuration is documented for PE branch production. Review the branch form, wire specification and mould-hole layout for the intended application.
Insertion take out and product placement
The source process describes wire insertion and branch handling around the moulding operation.
Feed and grip wires The wire box separates the wires, which are then gripped by the wire-handling structure.
Insert into the mould The robot moves in X, Y and Z directions to insert the wires into the mould holes.
Take out the branches After moulding is complete, the product grippers pick up the moulded Christmas tree branches.
Move to placement The robot moves the products to the placement position, and the handling cycle repeats.
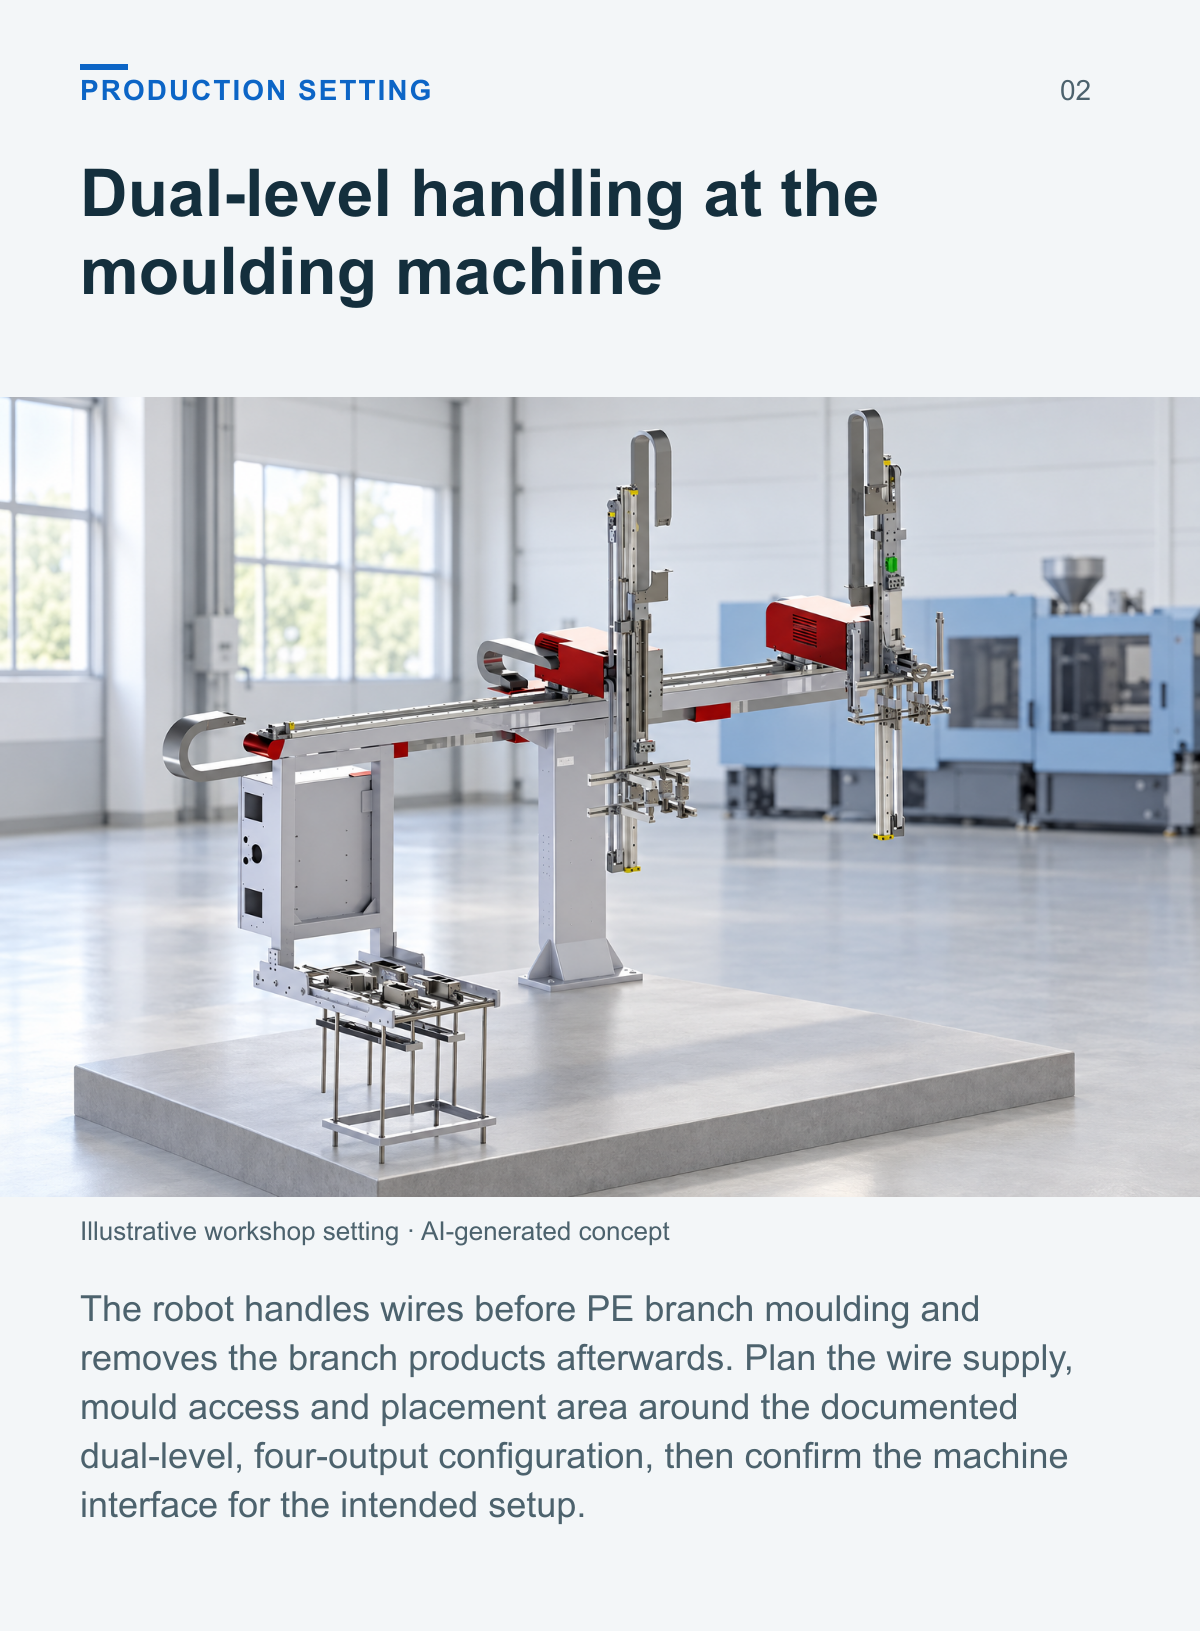
Dual level handling at the moulding machine
The robot handles wires before PE branch moulding and removes the branch products afterwards. Plan the wire supply, mould access and placement area around the documented dual-level, four-output configuration, then confirm the machine interface for the intended setup.
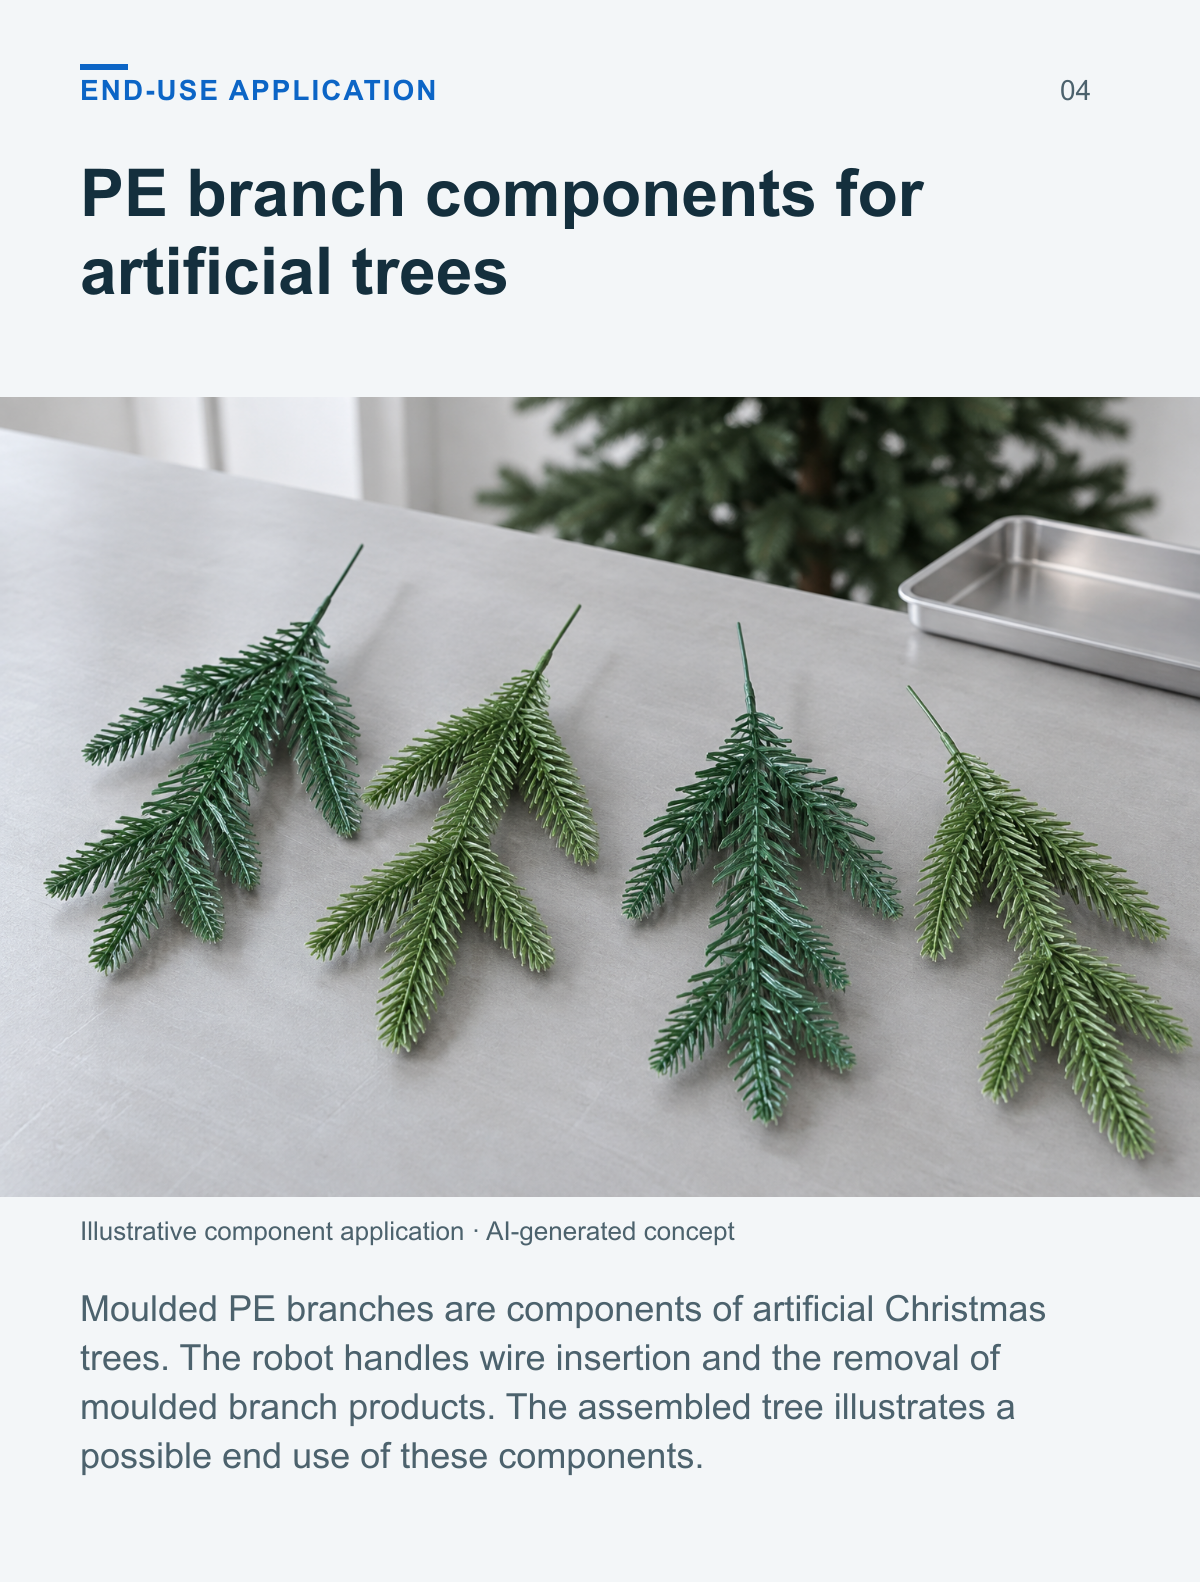
PE branch components for artificial trees
Moulded PE branches are components of artificial Christmas trees. The robot handles wire insertion and the removal of moulded branch products. The assembled tree illustrates a possible end use of these components.
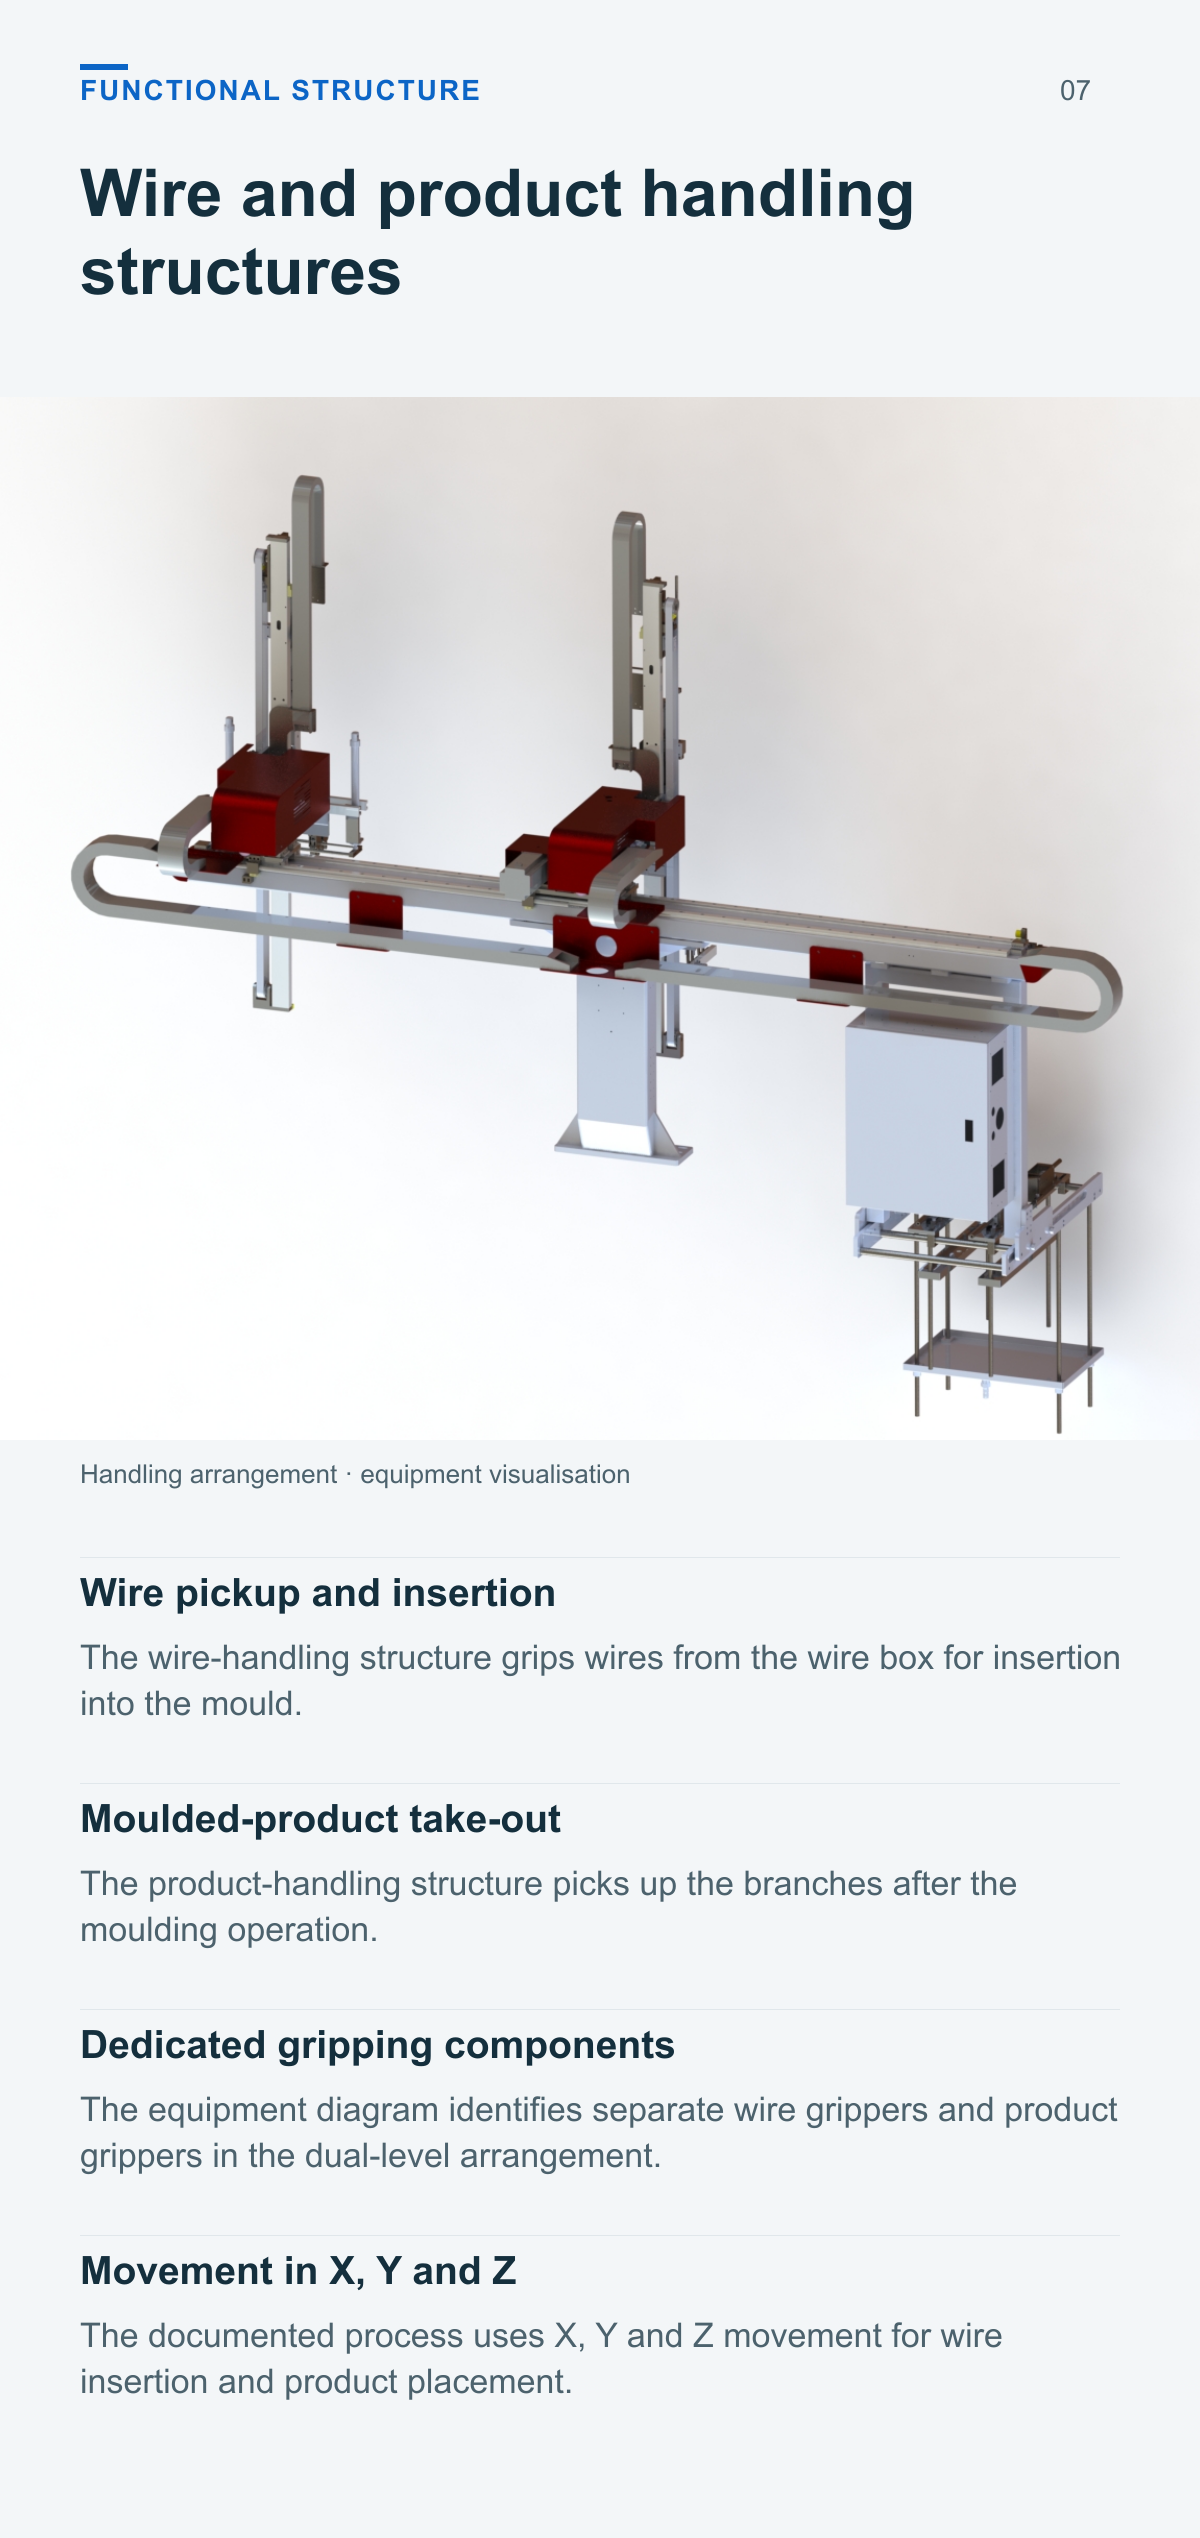
Wire and product handling structures
Wire pickup and insertion
The wire-handling structure grips wires from the wire box for insertion into the mould.
Moulded product take out
The product-handling structure picks up the branches after the moulding operation.
Dedicated gripping components
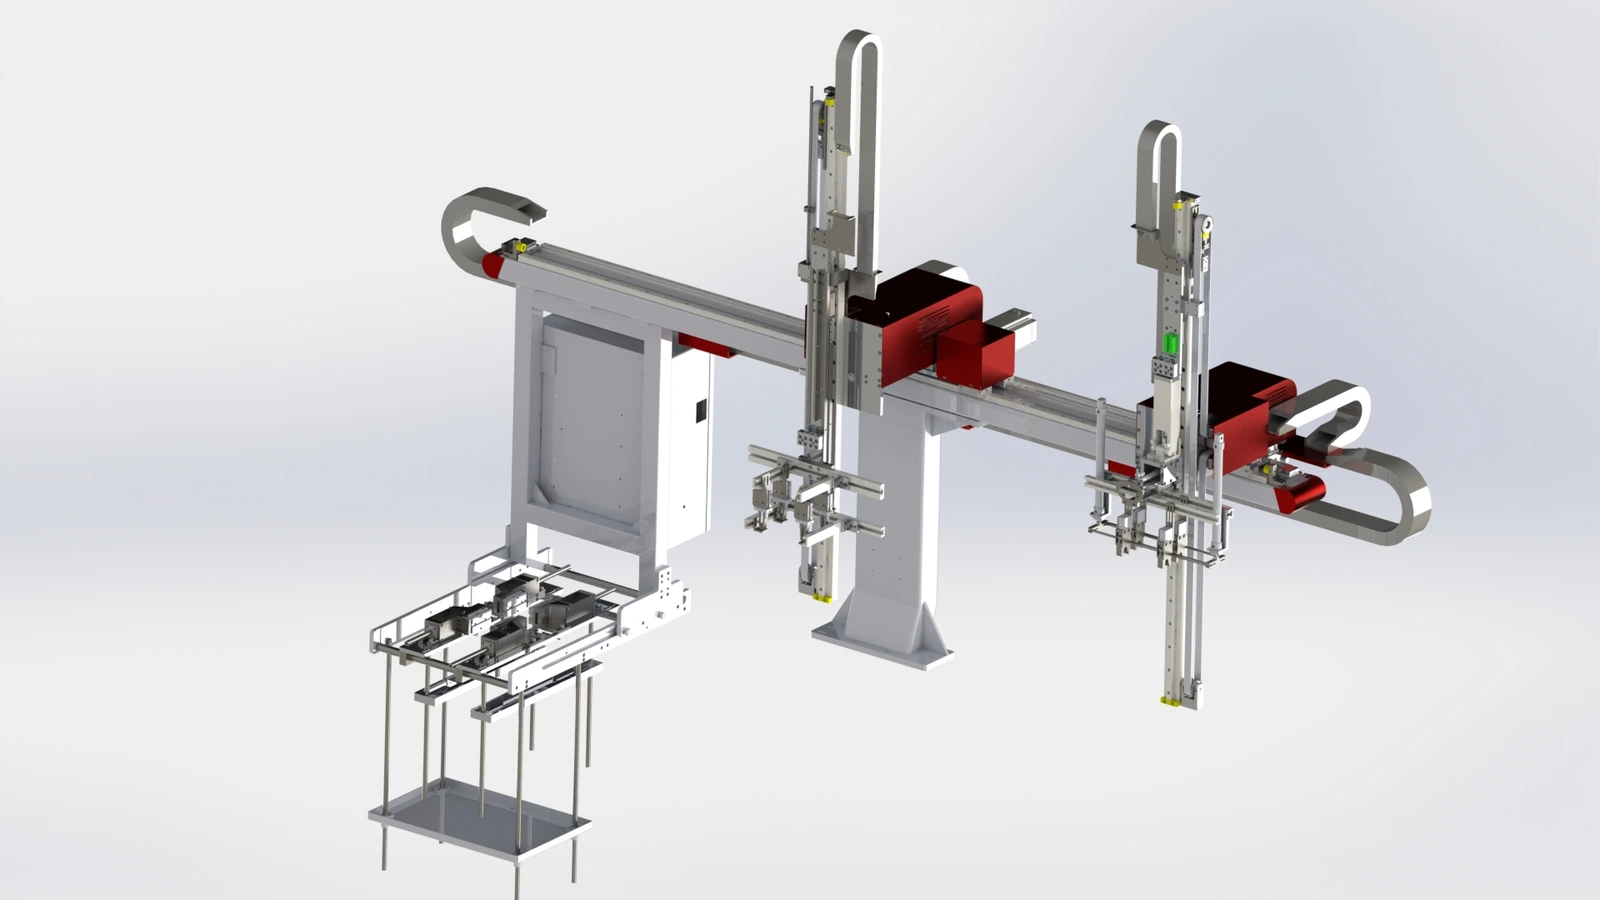
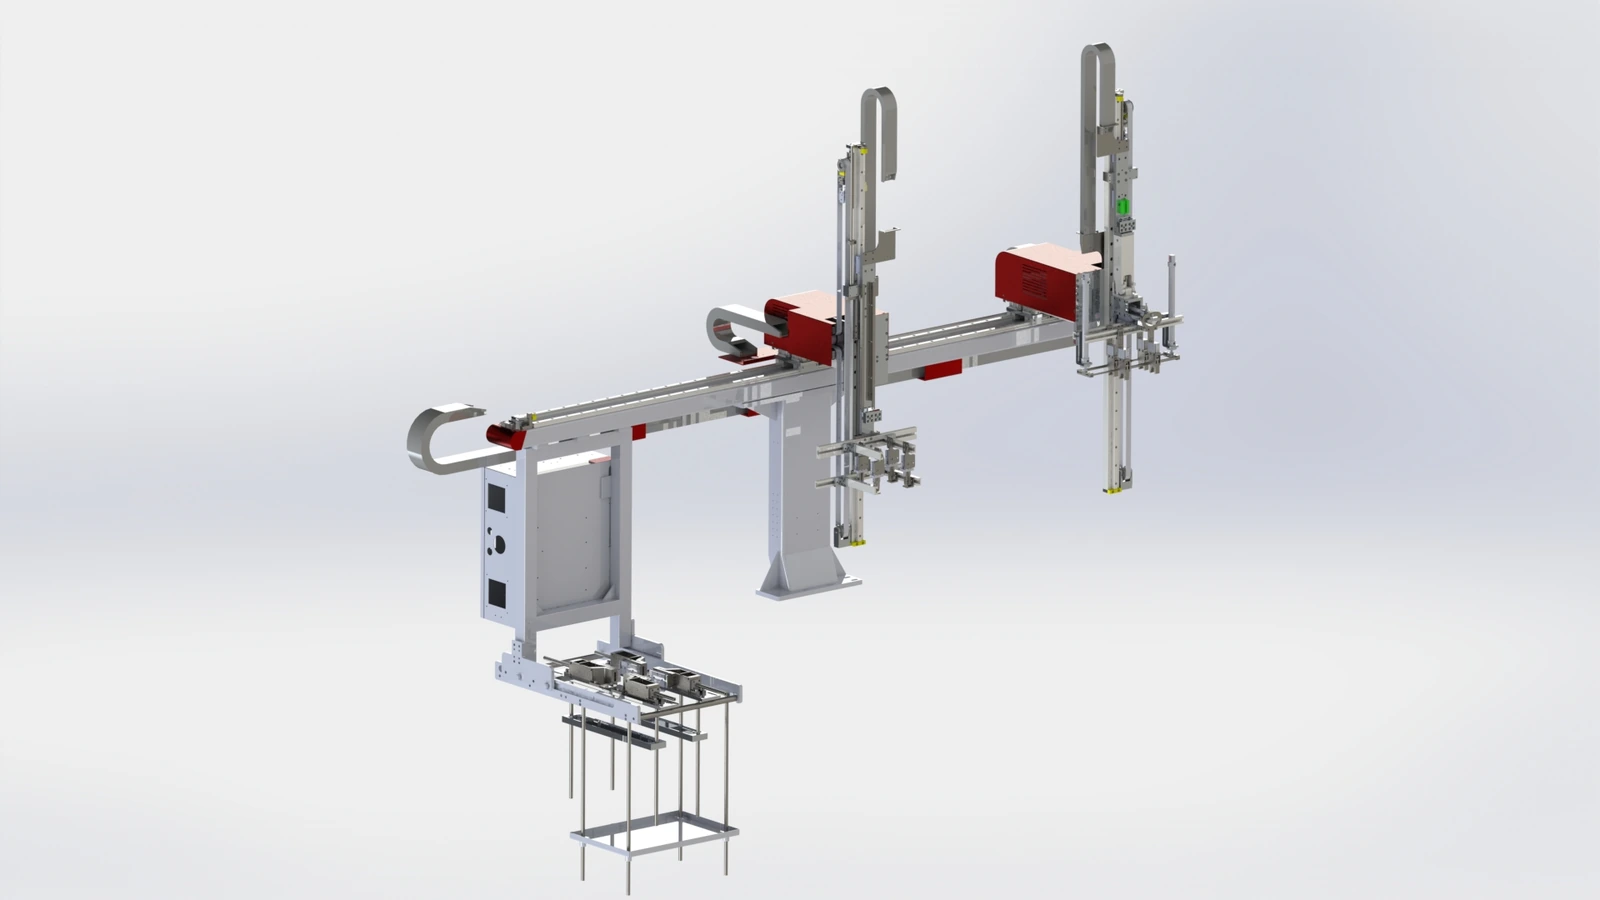
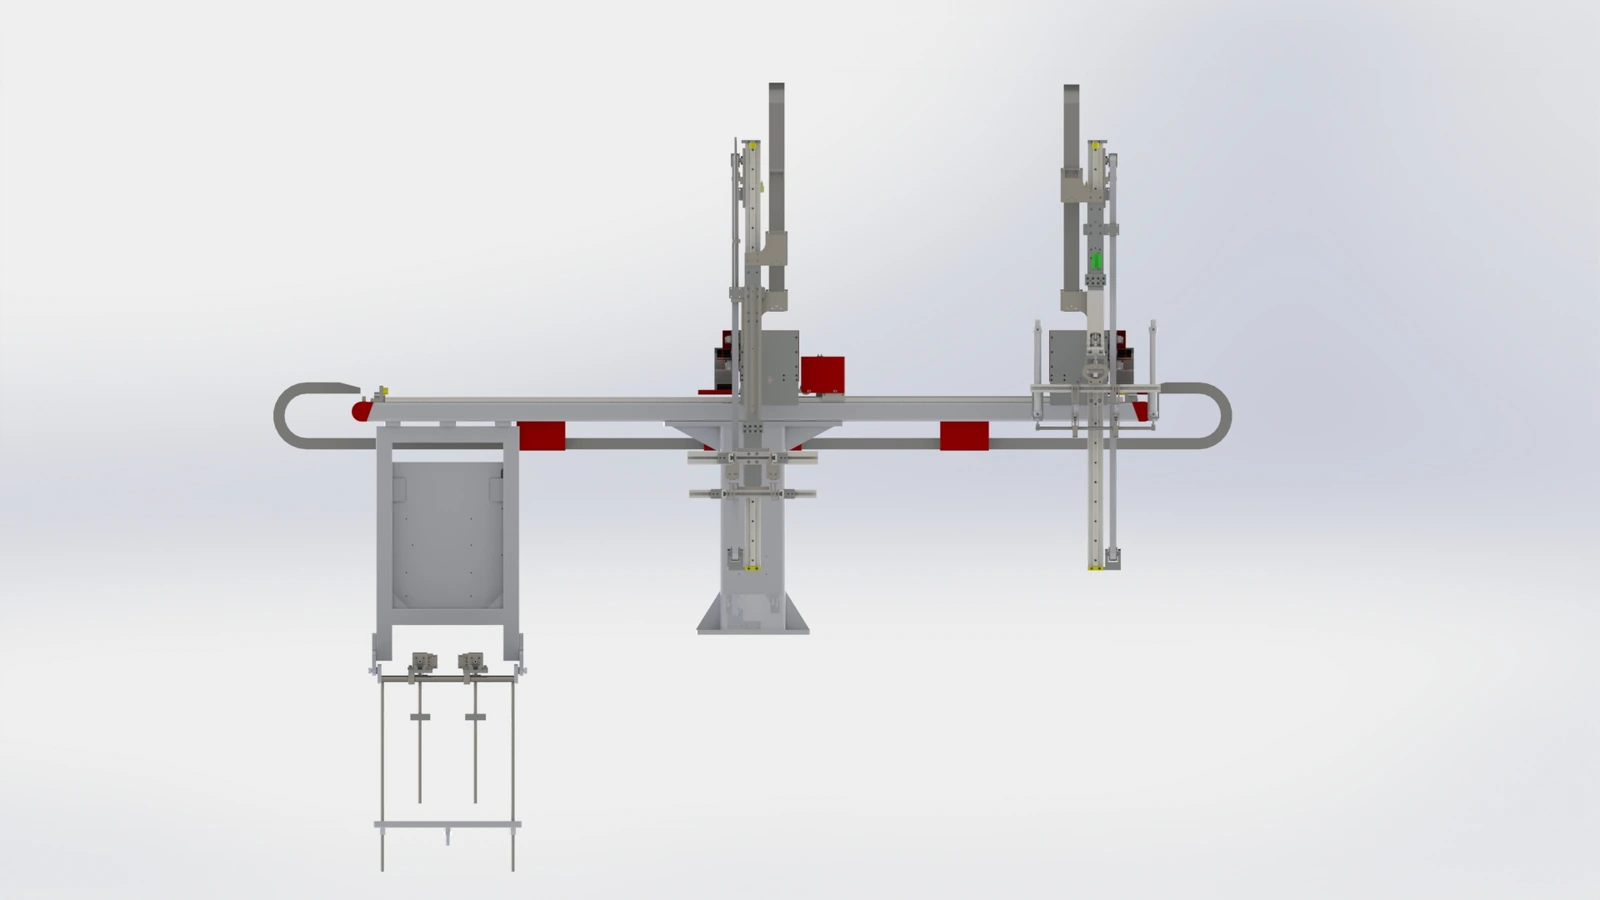
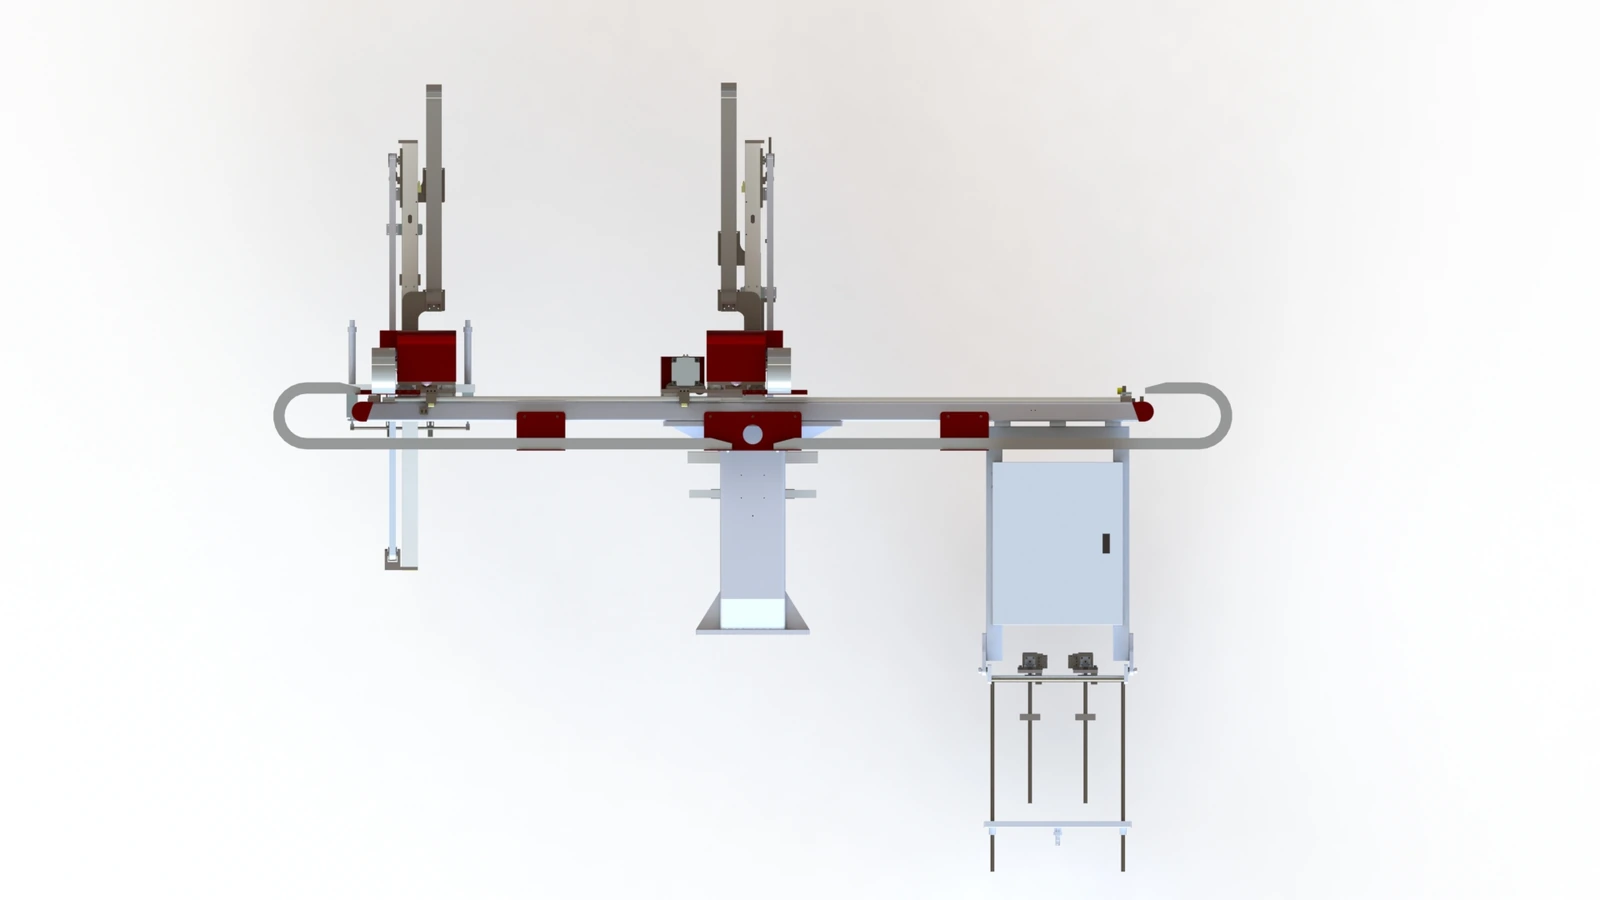
The equipment diagram identifies separate wire grippers and product grippers in the dual-level arrangement.
Movement in X Y and Z
The documented process uses X, Y and Z movement for wire insertion and product placement.
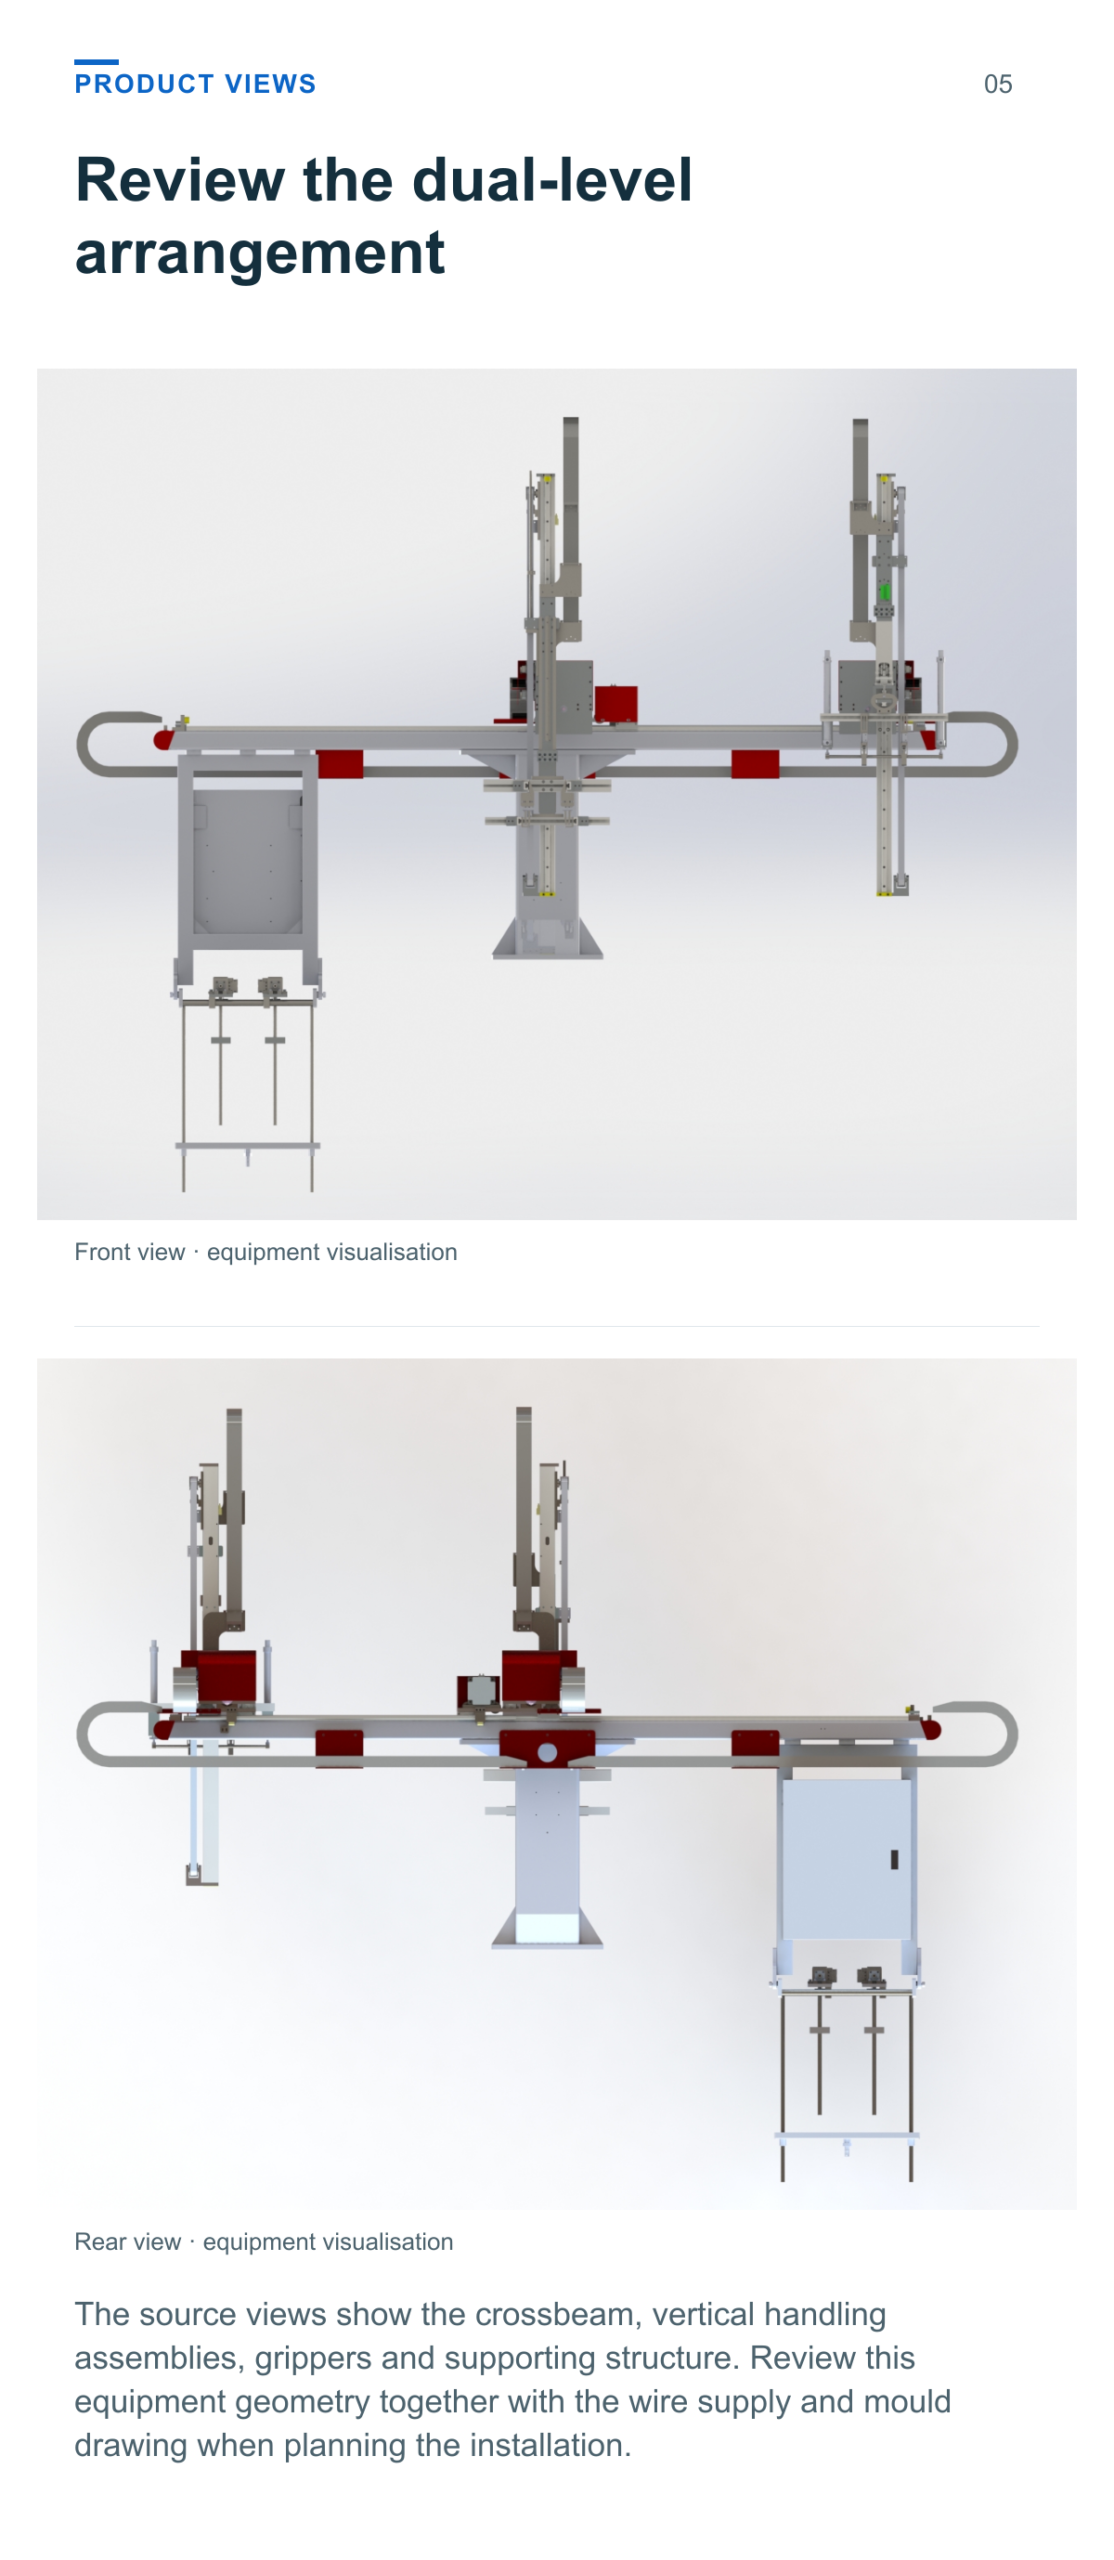
Review the dual level arrangement
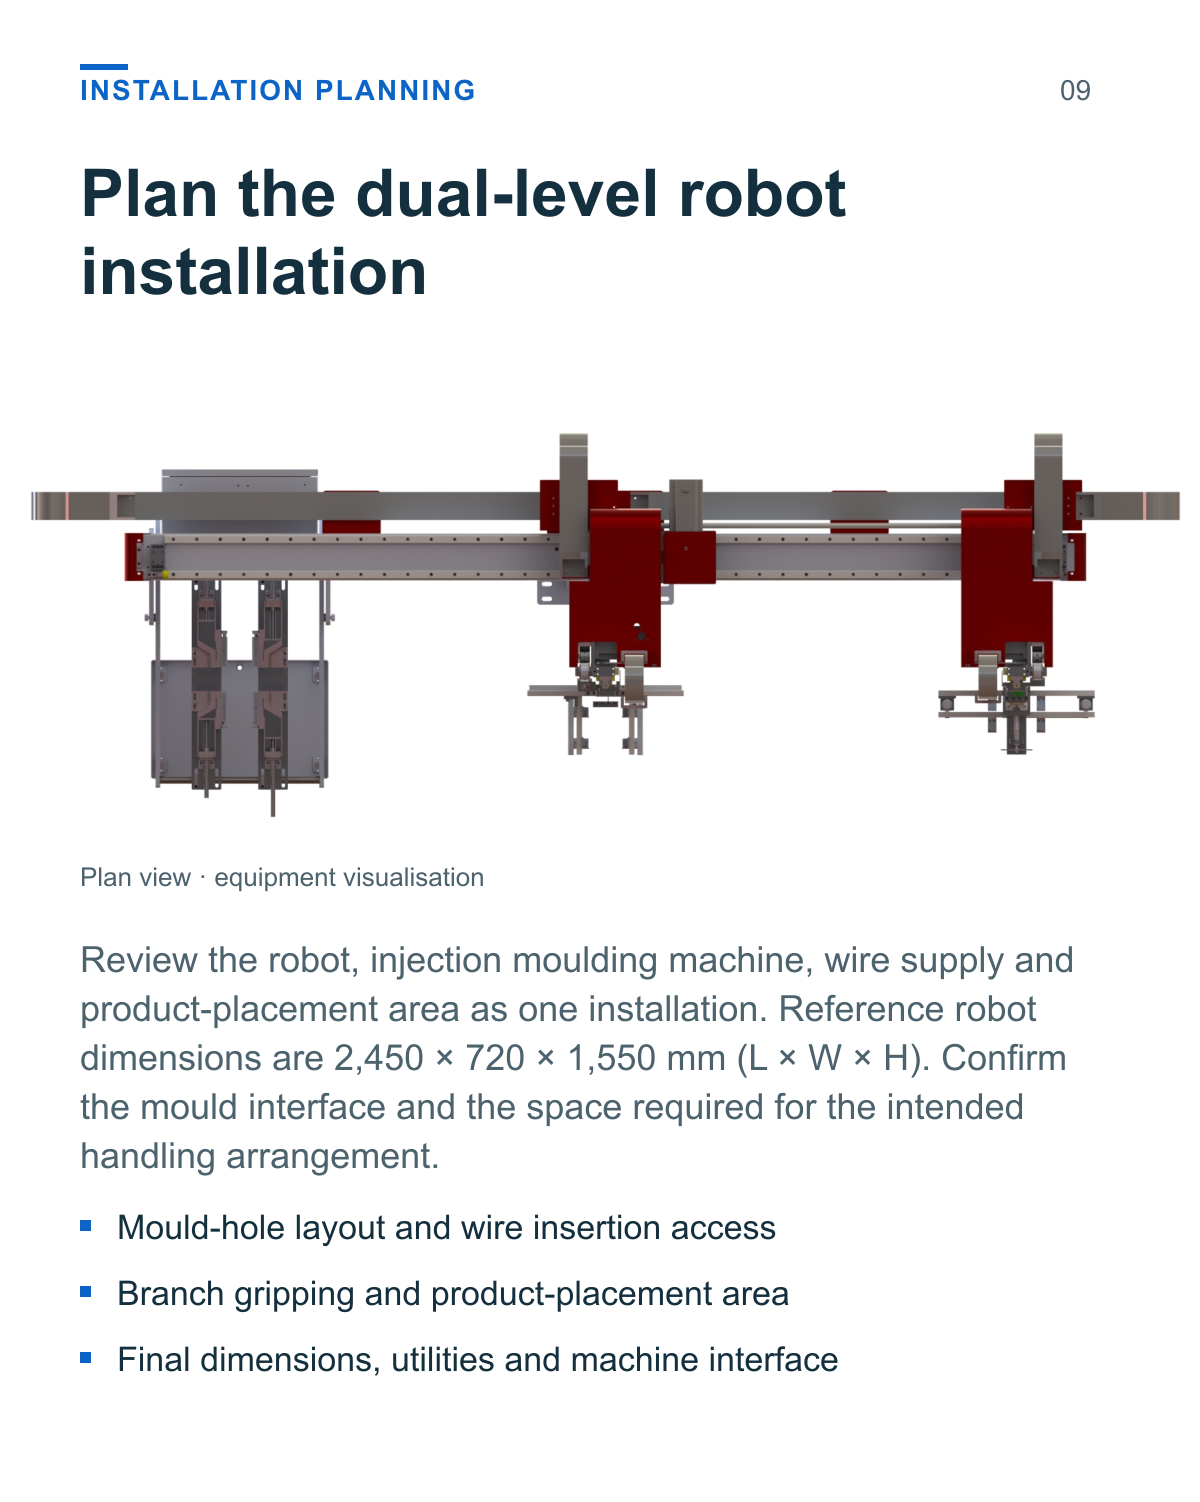
The source views show the crossbeam, vertical handling assemblies, grippers and supporting structure. Review this equipment geometry together with the wire supply and mould drawing when planning the installation.
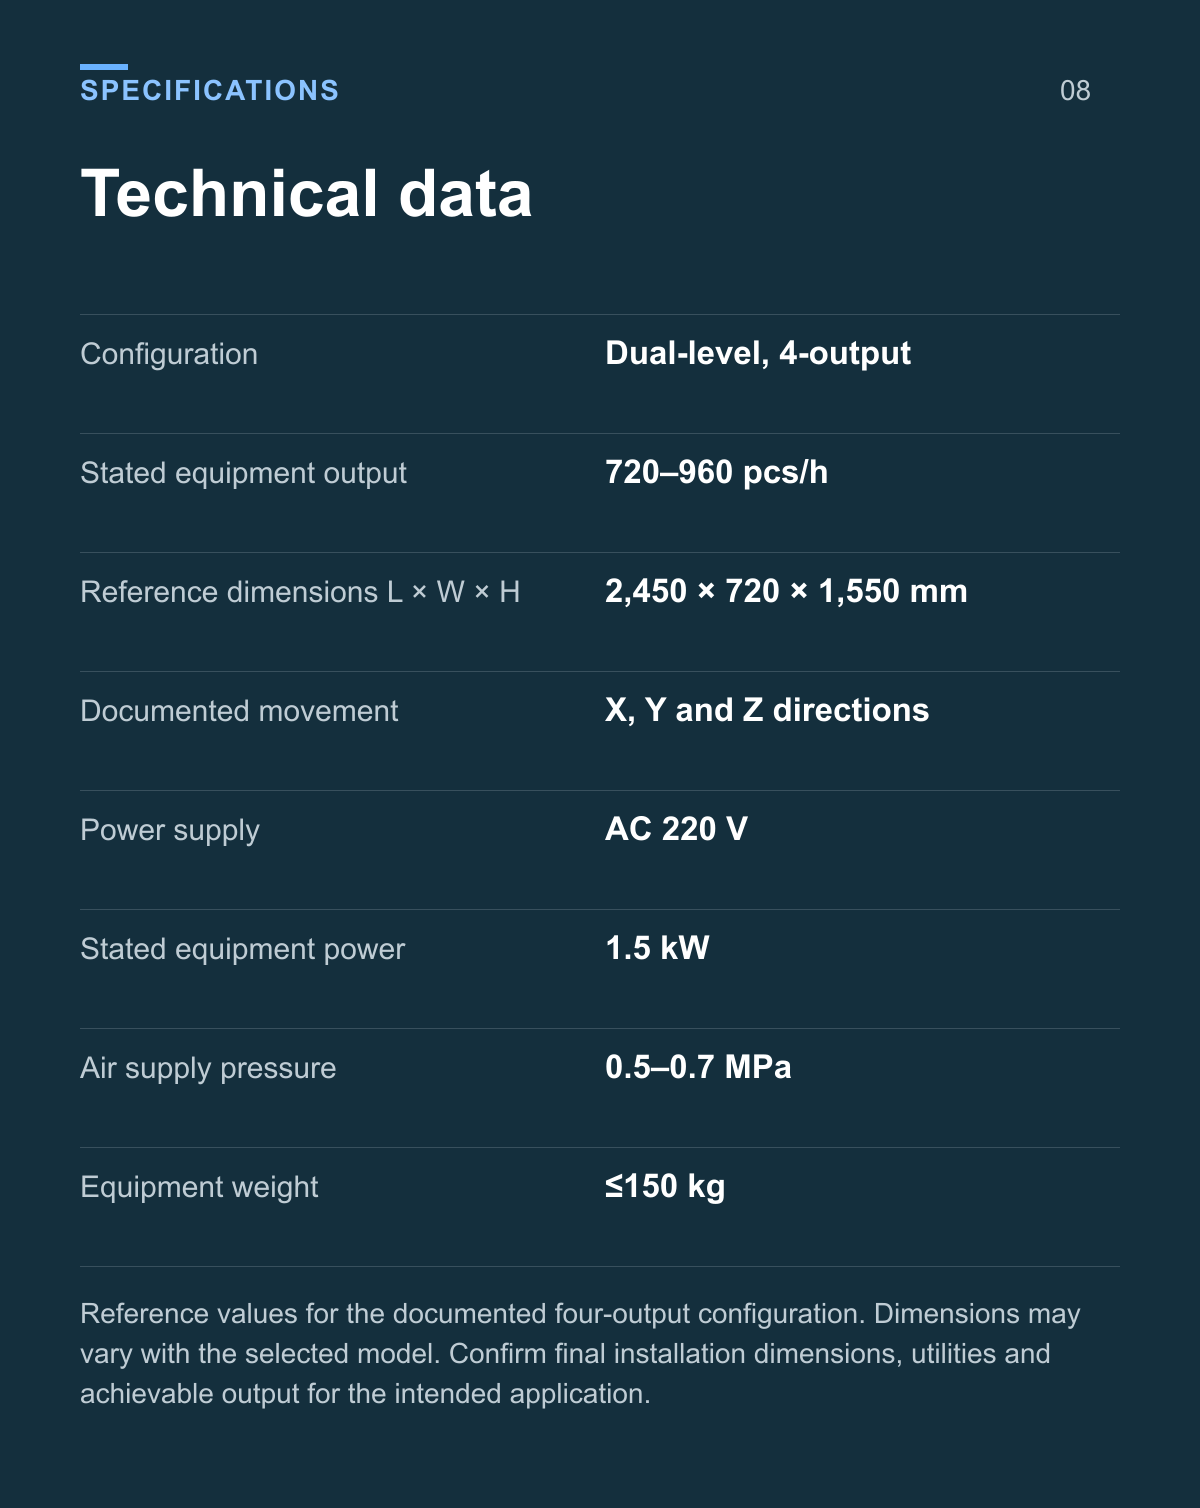
Technical data
| Parameter | Value |
|---|---|
| Configuration | Dual-level, 4-output |
| Stated equipment output | 720–960 pcs/h |
| Reference dimensions L × W × H | 2,450 × 720 × 1,550 mm |
| Documented movement | X, Y and Z directions |
| Power supply | AC 220 V |
| Stated equipment power | 1.5 kW |
| Air supply pressure | 0.5–0.7 MPa |
| Equipment weight | ≤150 kg |
Reference values for the documented four-output configuration. Dimensions may vary with the selected model. Confirm final installation dimensions, utilities and achievable output for the intended application.
Plan the dual level robot installation
Review the robot, injection moulding machine, wire supply and product-placement area as one installation. Reference robot dimensions are 2,450 × 720 × 1,550 mm (L × W × H). Confirm the mould interface and the space required for the intended handling arrangement.
- Mould-hole layout and wire insertion access
- Branch gripping and product-placement area
- Final dimensions, utilities and machine interface
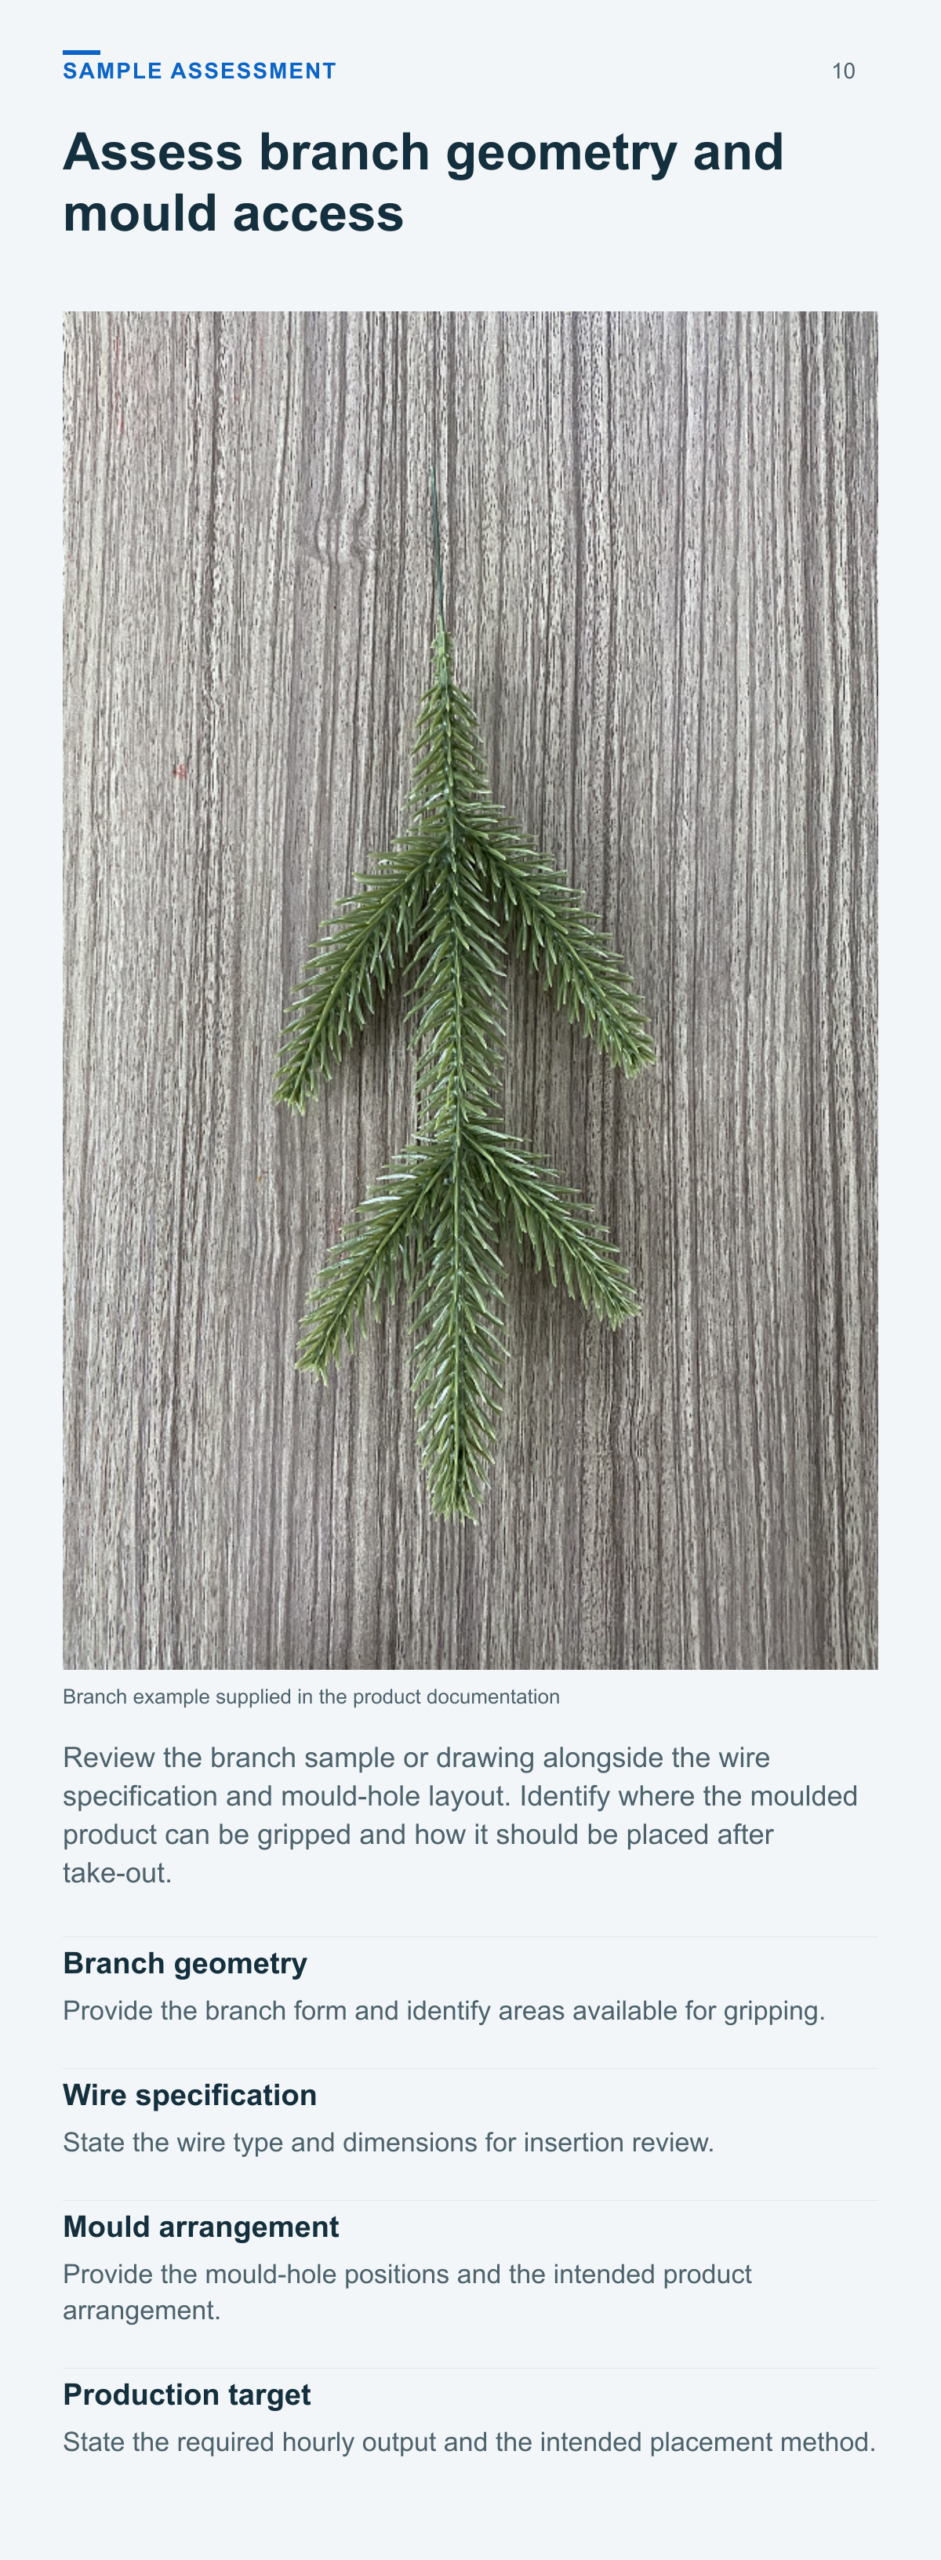
Assess branch geometry and mould access
Review the branch sample or drawing alongside the wire specification and mould-hole layout. Identify where the moulded product can be gripped and how it should be placed after take-out.
Branch geometry
Provide the branch form and identify areas available for gripping.
Wire specification
State the wire type and dimensions for insertion review.
Mould arrangement
Provide the mould-hole positions and the intended product arrangement.
Production target
State the required hourly output and the intended placement method.
Application questions
What does the 4 output configuration mean
The source specification describes a model producing four products at a time. The stated equipment output is 720–960 pcs/h, already specified for the four-output configuration.
Which parts of the process does the robot handle
The documented sequence covers wire pickup, insertion into mould holes, take-out of moulded branches and product placement. Confirm the required timing with the intended injection moulding machine.
What is needed to assess a branch design
Provide the branch sample or drawing, wire specification and mould-hole layout. These support the review of wire insertion, product gripping and placement for the intended setup.
Does the robot include the injection moulding machine
This product is the wire-insertion and take-out robot. Confirm the injection moulding machine interface and the final scope of supply for the complete installation.
Define your dual level branch setup
Provide branch samples or drawings, wire details, the mould-hole layout, required hourly output and injection moulding machine information to review the suitable four-output robot configuration.
Product views and application details